07 · Engineering & research
Robotics and product career
My product judgement rests on twelve years of building robots that had to work beyond the prototype: industrial and educational cobots, mobile logistics robots, humanoid and social robots and assistive arms, always with reliable software, clear interfaces between teams and deployment in mind from day one.
- 2024–2026
ISIR, CNRS
R&D engineer · Extender projectFunctional and software definition of robotic assistance for people with disabilities, under constraints of use, safety and acceptability. I specified and prioritised supervision, teleoperation and control features on real robots, through iteration workshops with industrial partners, clinical teams and end users. See the Bloom case study.
- 2022–2024
SaaS software products
Advisor & co-founderProduct framing, market and use-case analysis, user journeys and feature prioritisation for Banana Army and Rumble Studio, now spOken, where I remain advisor and shareholder. Prototyping, roadmap structuring and consolidating user feedback to steer product choices.
- 2021–2022
Niryo
Technical leadI led the software and product roadmap of Ned2, an industrial and educational robot arm, with a 7-person software team and UX contractors, balancing user needs, technical constraints, industrialisation and deadlines.
- Tracked priorities, deliverables and hardware and software dependencies.
- Set validation milestones and software quality, and planned EMC constraints in with the dedicated quality engineer.
- Launched Ned2 at CES 2022, and made architecture choices that later fed into the Nate platform.
- 2019–2021
SoftBank Robotics Europe
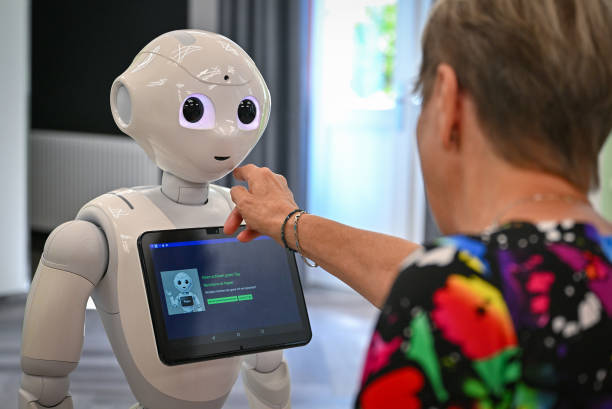
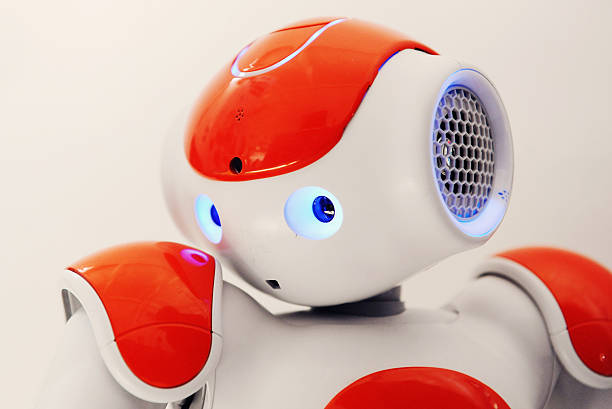
R&D engineerHuman-robot interaction and perception modules for humanoid robots used in the field, with attention to user experience and observable behaviour. Development tracked in Jira and validated in real conditions.
- Environment awareness and perception strategies for social interaction.
- Affective computing, NLP and expressive, emotion-aware speech synthesis.
- Cross-team work in the European H2020 ANIMATAS project, and student supervision.
- 2018–2019
Movu Robotics
Technical leadFunctional requirements and software integration for mobile logistics robots deployed in production, in a constrained industrial environment. I coordinated operational use, human-robot interaction, sensors, localisation, navigation and system integration for the first 15 robots deployed.
- 2014–2018
What this experience includes
- Architecture
- Complex robotic software systems in C/C++, Python and ROS, and web stacks in React, Angular and FastAPI.
- Coordination
- Between software, hardware, UX, production, contractors and prospective clients.
- Quality
- Validation and deployment thinking for robots used beyond the lab.
- Perception
- Navigation and interaction for robots in constrained environments.
- Tools
- Git, Jira, ClickUp, Notion, Figma and Miro, on Linux, Windows and Android.